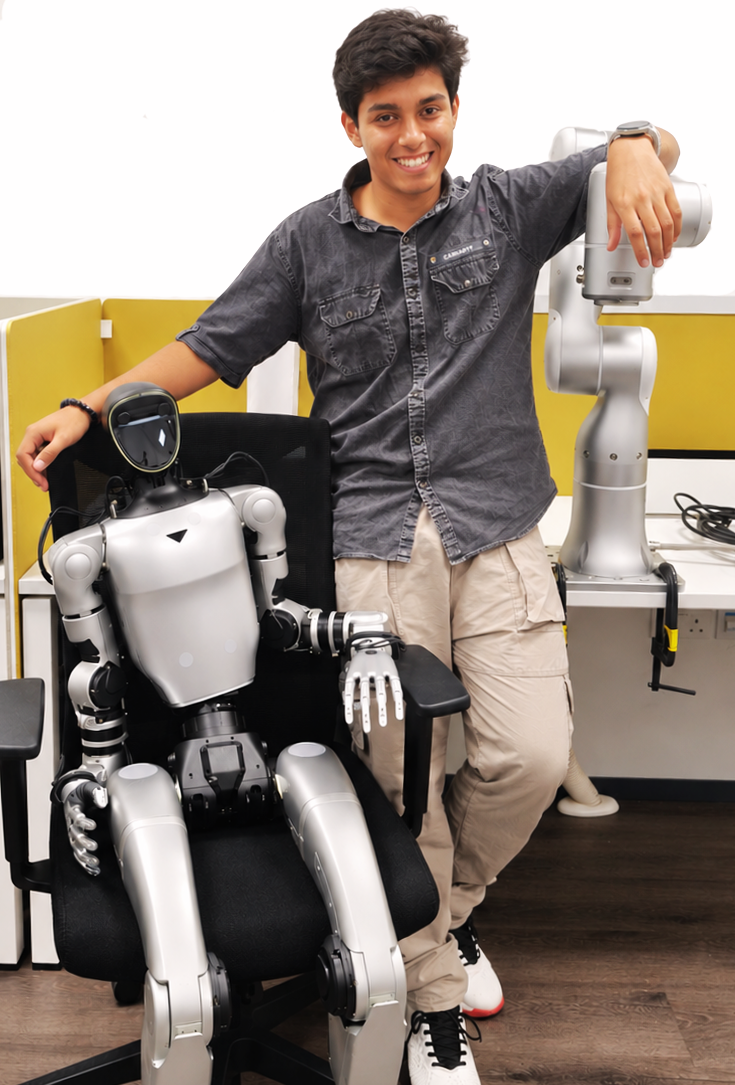
Shailesh
(Legally, it's just Shailesh. Some systems insist otherwise, hence "Shailesh Shailesh.")
I’m a Research Assistant at the MAGIC Lab, National University of Singapore (NUS), working with Prof Jiafei Duan. I received my Bachelor of Technology in Electrical Engineering (Minor in Embedded Systems) from IIT Dhanbad.
Previously, I was a Research Intern → Research Assistant at the MARMoT Lab, NUS, working with Prof Guillaume Sartoretti. I’ve also spent time at CIR, IIIT Allahabad with Prof G.C. Nandi.
My research aims to develop foundation models that enable general-purpose robot learning. This spans three interconnected threads, vision-language-action models, world models, and test-time scaling; unified by a common goal: robots that generalize robustly to real-world manipulation tasks.
🔥 News
- [2026/09] Our work GAM is out, check it out here.
- [2026/09] Our work LIT is out, check it out here.
- [2026/07] Joined the MAGIC Lab, National University of Singapore (NUS) as a Research Assistant, working with Prof Jiafei Duan.
- [2026/07] Our work RL^2-VLA is out, check it out here.
- [2025/11] Our work GRIM has been accepted to AAAI 2026 (Oral). See you guys in Singapore 🇸🇬
- [2025/09] GRIM was selected as Best Paper Finalist at RemembeRL @ CoRL 2025.
- [2025/06] Our work GRIM is out, check it out here.
- [2025/06] Joined the MARMoT Lab, National University of Singapore (NUS), working with Prof Guillaume Sartoretti.
- [2025/05] Our work Search-TTA was accepted to CoRL 2025, check it out here. See you guys in Seoul :) 🇰🇷
📑 Publications
💼 Experience
MAGIC Lab, National University of Singapore (NUS)
Research Assistant, under Prof Jiafei DuanJul 2026 - Present
MARMoT Lab, National University of Singapore (NUS)
Research Intern → Research Assistant, under Prof Guillaume SartorettiJun 2025 - Jul 2026
CIR, IIIT Allahabad [video]
Research Intern, under Prof G.C. Nandi & Andrew MelnikAug 2024 - May 2025
ERC Lab, National Taiwan Normal University (NTNU) [video]
Robotics Intern, under Prof Saeed Saeedvand & Prof Jacky BaltesMay 2024 - Jul 2024
Stochastic Robotics Lab, IISc Bangalore
Robotics Intern, under Prof Shishir Kolathaya NYDecember 2023
TEXMiN (Technology Innovation Hub) [video]
Project Assistant, under Prof Arun Dayal UdaiFeb 2023 - Apr 2024
📖 Academic Services
Reviewer
🎓 Education
IIT Dhanbad
Class of 2025
Bachelor of Technology in Electrical Engineering (Minor in Embedded Systems)
- Relevant Coursework: Data Structures & Algorithms, Probability & Statistics, Modern Control, Embedded System Design.
- MOOCs: Reinforcement Learning Specialization (University of Alberta / AMII, Coursera).
🏅 Honors and Awards
- Best Paper Finalist: RemembeRL @ CoRL 2025 (with GRIM)
- Scholarship: TEEP@AsiaPlus 2024
- 1st Position ($12,000): Robofest Gujarat 3.0 2023 (India’s Biggest Robotics Competition)
- 1st Position: Vichesta (ROS simulation competition), Takshak 2022 (Hosted by IIT, Dhanbad)
- 3rd Position: Robowars (BattleBots) at Concetto 2022 (Hosted by IIT, Dhanbad)
🎲 Misc
- Sports: Badminton, Tennis (beginner)
- Art: I draw sometimes, check it out here
- Fun projects: CNC Plotter, Lunar Scout